

H∞ controller design for Nabla discrete fractional-order systems
Jin-Xi Zhang1, Yuanda Lv2, Xuefeng Zhang2
1State Key Laboratory of Synthetical Automation for Process Industries, Northeastern University, Shenyang, 110819, China.

Abstract:
This article aims to provide several criteria with sufficient conditions for Nabla discrete fractional-order systems to satisfy a certain H∞ performance index. Firstly, the instability region is approximated by a series of union sets of fan-shaped domains, and the mathematical expression of each fan-shaped domain is given. Secondly, by using the above approximation method and the generalized Kalman-Yakubovič-Popov lemma, some criteria with linear matrix inequality (LMI) formulations for the boundedness of the H∞ norm of the transfer function matrix for Nabla discrete FOSs are derived. Thirdly, an LMI-based H∞ state feedback controller design method is provided by using the projection lemma, which is aimed to stabilize the system and optimize its H∞ performance index simultaneously. Finally, the effectiveness of the proposed approach is verified by the accurate numerical solutions and system state responses obtained from two simulation examples.


Related Concept Videos
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:24
PI Controller: Design
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:22
Phase-lead and Phase-lag Controllers
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
First Order Systems
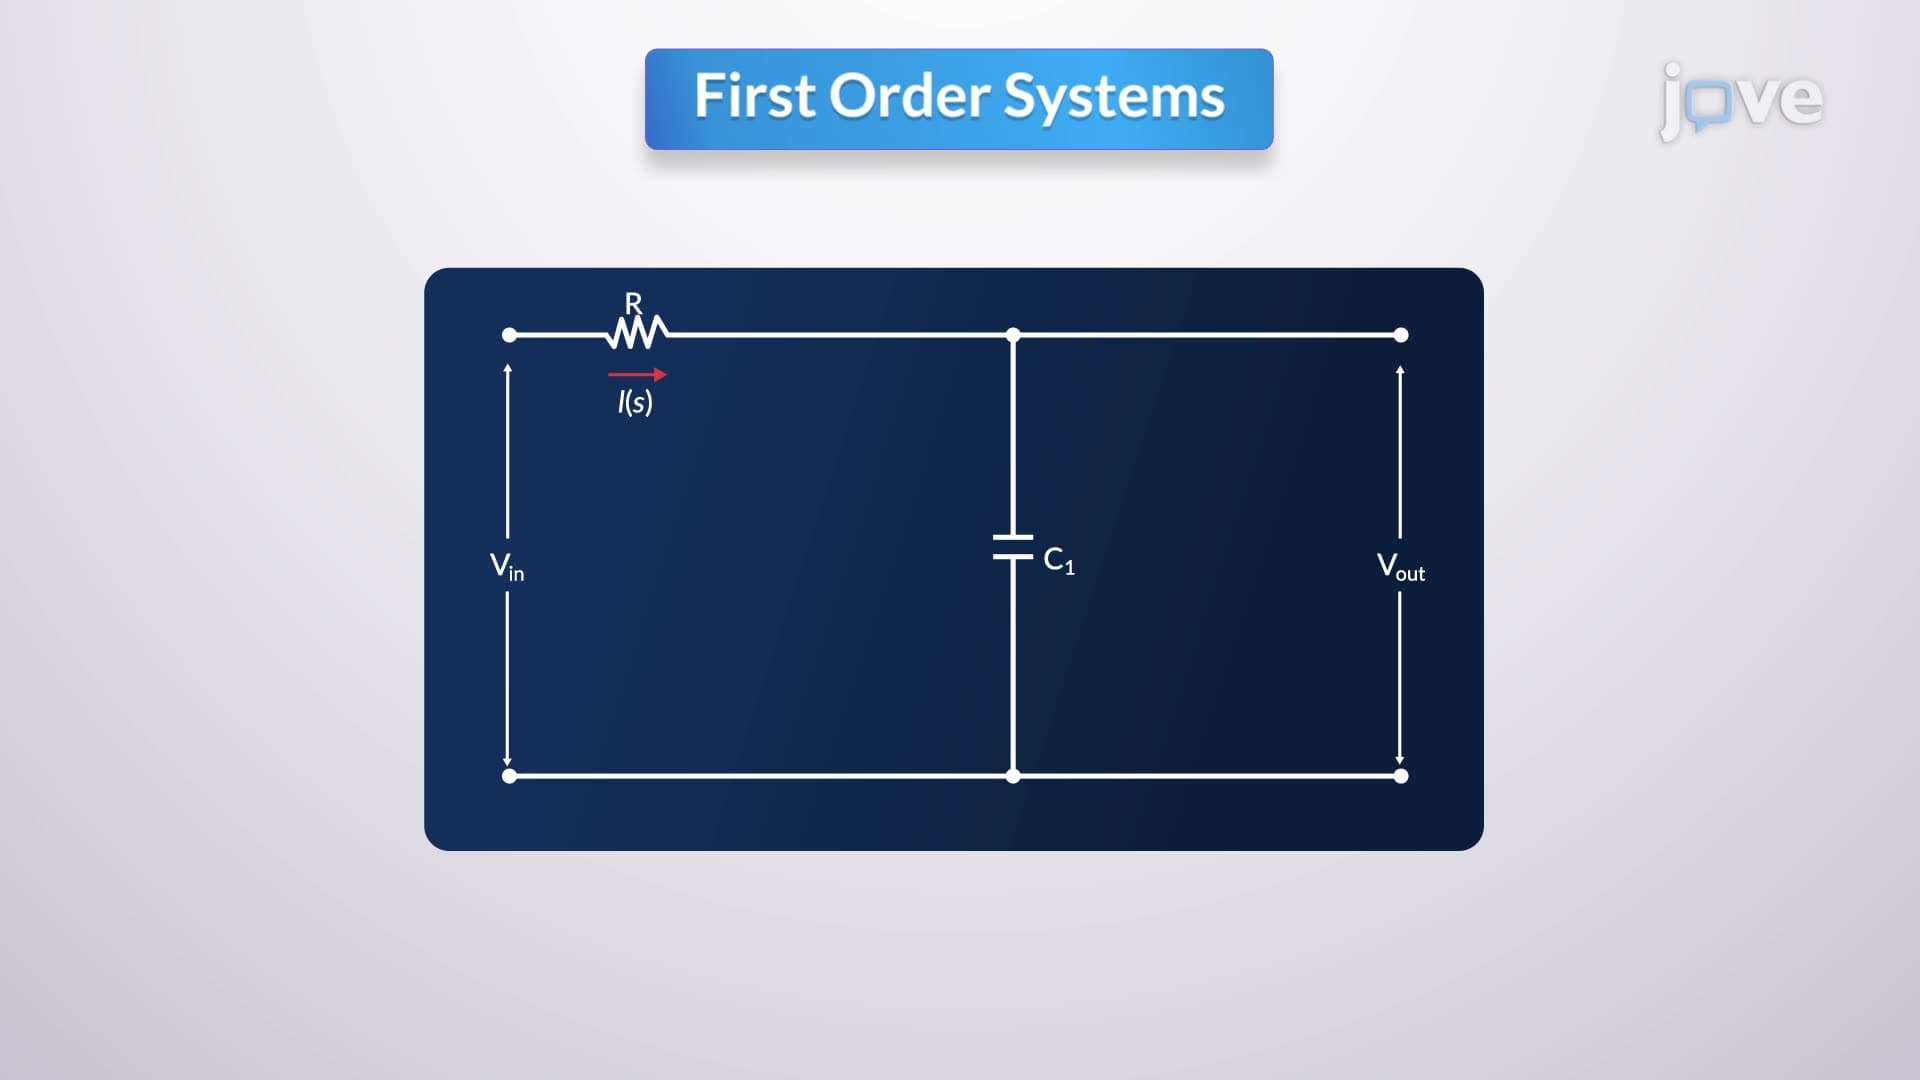
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...