Related Experiment Video
Updated: May 10, 2026


Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Enhancing Human-Robot Compatibility in Shoulder Exoskeletons: Passive Joint Optimization of PPRRRP vs. RRRUP
Qiang Cao1, Wenhao Shan1, Yue Liu1
1The College of Machine, Shanghai DianJi University, Shanghai 201306, China.

Abstract:
This study aims to evaluate the kinematic performance of two shoulder rehabilitation exoskeleton configurations to address the critical challenge of human-robot compatibility. Utilizing Hunt's mobility formula and task-specific Jacobian analysis, we developed a closed-chain kinematic model integrating transient glenohumeral joint dynamics, validated through force/torque measurements and ANOVA statistical comparisons. The PPRRRP configuration, featuring orthogonally distributed passive prismatic joints, demonstrated superior performance: 40-60% lower interaction forces (F¯total=2.66 N), near-isotropic manipulability (ellipsoid axis ratio < 1.5), and 60% reduced operational torque (T¯total=0.18 N·m) compared to RRRUP's universal joint design. These results establish passive DOF optimization as a viable alternative to actuator-dense systems, diverging from conventional approaches like ARMin-III that prioritize active control. The originality lies in bridging theoretical configuration synthesis with empirical validation, offering a replicable framework for compatibility assessment. This work advances rehabilitation robotics by demonstrating that mechanical transparency-achieved through strategic passive joint allocation-enhances natural movement synergy without compromising stability, proposing hypotheses on energy efficiency and isotropy-fatigue correlations for future exploration. Clinical translation and adaptive impedance control integration are identified as critical next steps to optimize patient-specific rehabilitation outcomes.
More Related Videos
 03:55
Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
Related Concept Videos
 01:19
Bones of the Upper Limb: Humerus
 01:15
Bones of the Upper Limb: Ulna
 01:09
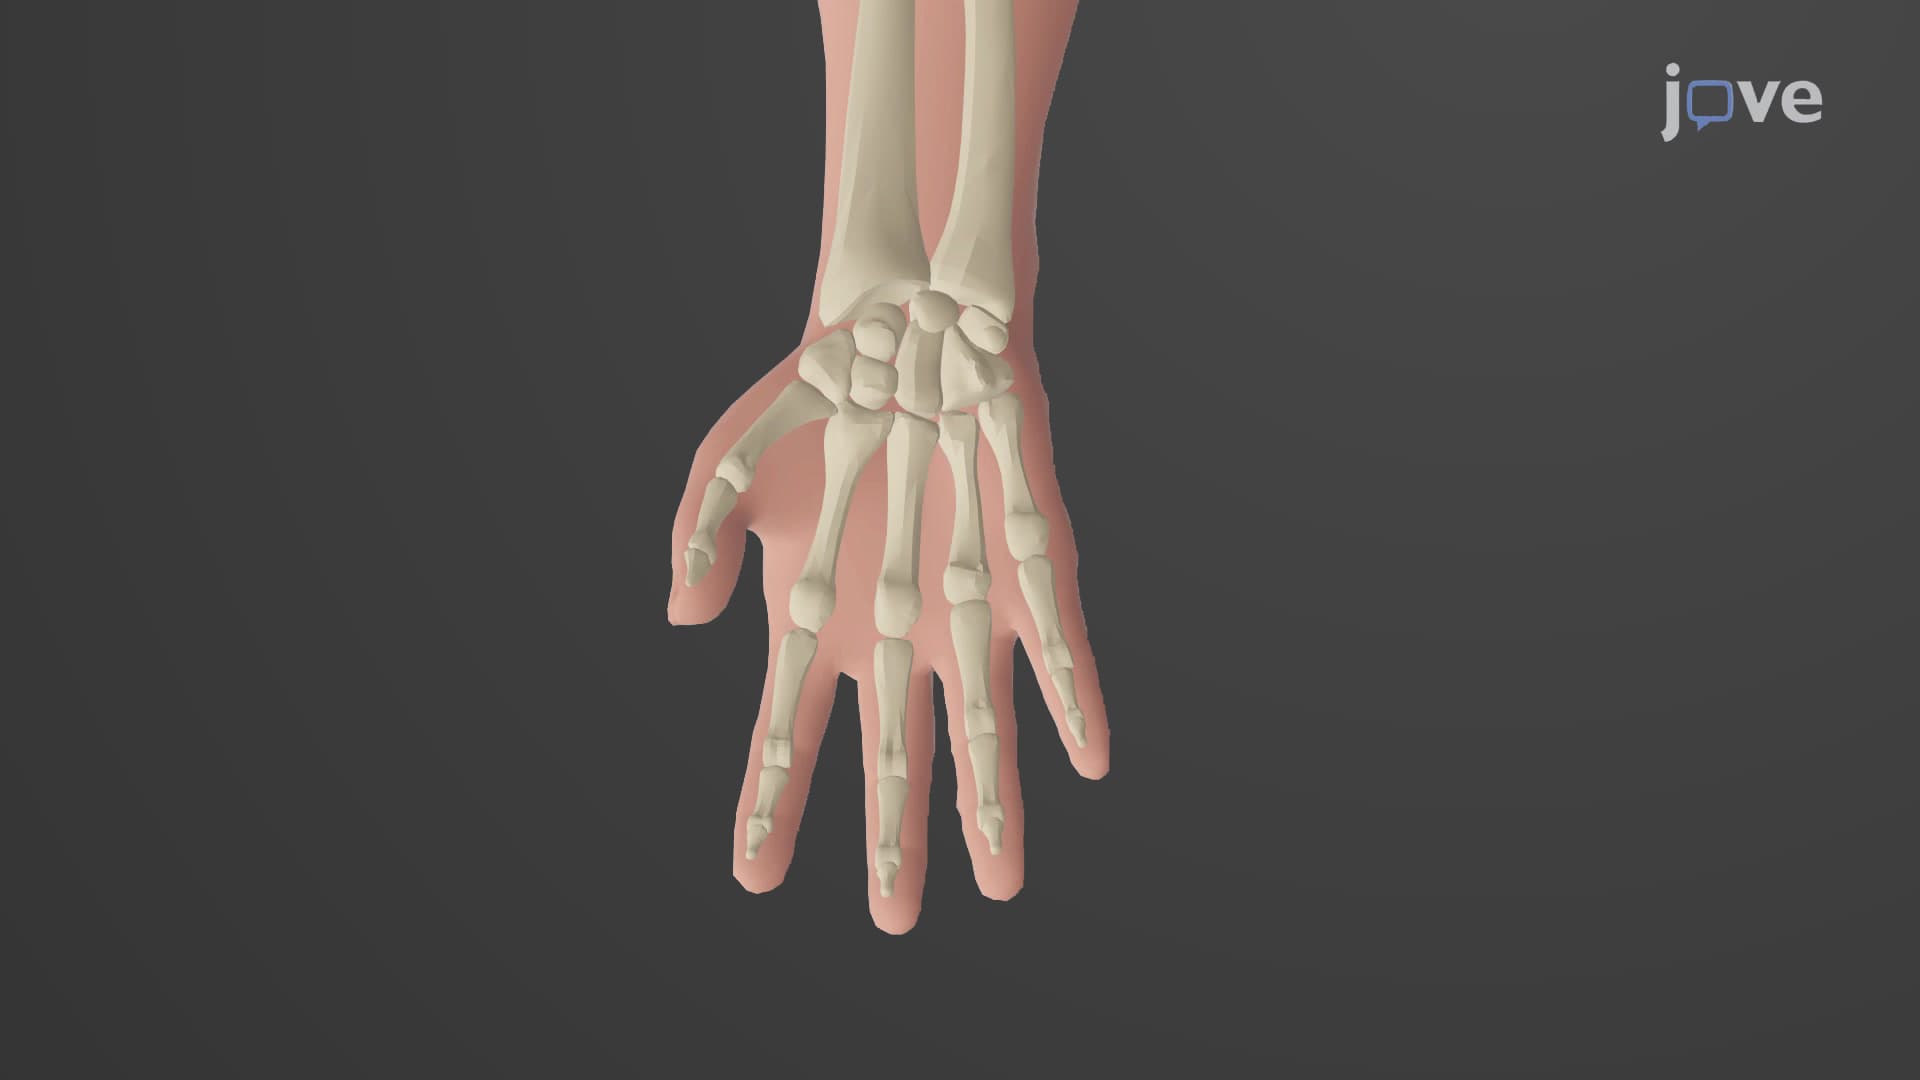
Bones of the Upper Limb: Radius
The radius has a nail-shaped head, and a short...
 01:16
Bones of the Lower Limb: Femur and Patella
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:25
Transformers with Off-Nominal Turns Ratios