Predicting driver adaptability: a computational rationality model for attention allocation in lateral vehicle control
Related Experiment Video
Updated: May 7, 2026
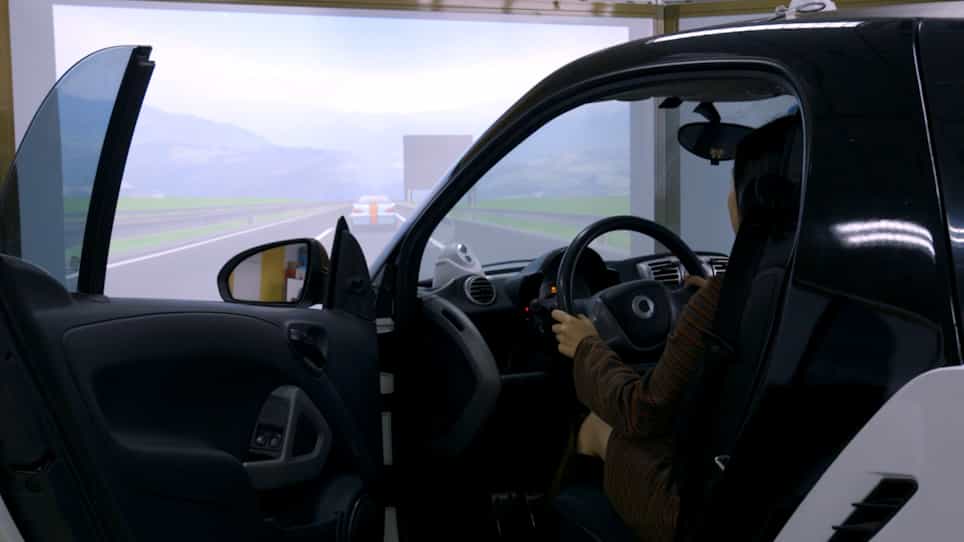
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
1Cognitive Science, Faculty of Information Technology, University of Jyväskylä, Jyväskylä, Finland.

Practitioner Summary:
Using computational rationality with reinforcement learning, the model predicts when drivers sample visual information and how they steer under occlusion. Adjustable parameters (steering skill and internal cautiousness) enable individualised fits capturing inter-driver variability. This informs early-stage driver-attention monitoring and assistance design, strengthening safety systems and reducing reliance on laboratory testing.
More Related Videos

Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:25
The Anchoring-and-Adjustment Heuristic
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:37
Reason and Intuition
 01:17
Rolling Resistance: Problem Solving