Related Experiment Video
Updated: Feb 8, 2026

Imaging Integrin Tension and Cellular Force at Submicron Resolution with an Integrative Tension Sensor
Published on: April 25, 2019
Decentralized coordinated control of elastic web winding systems without tension sensor
Hailiang Hou1, Xiaohong Nian2, Jie Chen3
1School of Information Science and Engineering, Central South University, Changsha, Hunan Province, 410075, China; School of Information, Hunan University of Humanities, Science and Technology, Loudi, Hunan Province, 417000, China.

Abstract:
In elastic web winding systems, precise regulation of web tension in each span is critical to ensure final product quality, and to achieve low cost by reducing the occurrence of web break or fold. Generally, web winding systems use load cells or swing rolls as tension sensors, which add cost, reduce system reliability and increase the difficulty of control. In this paper, a decentralized coordinated control scheme with tension observers is designed for a three-motor web-winding system. First, two tension observers are proposed to estimate the unwinding and winding tension. The designed observers consider the essential dynamic, radius, and inertial variation effects and only require the modest computational effort. Then, using the estimated tensions as feedback signals, a robust decentralized coordinated controller is adopted to reduce the interaction between subsystems. Asymptotic stabilities of the observer error dynamics and the closed-loop winding systems are demonstrated via Lyapunov stability theory. The observer gains and the controller gains can be obtained by solving matrix inequalities. Finally, some simulations and experiments are performed on a paper winding setup to test the performance of the designed observers and the observer-base DCC method, respectively.
More Related Videos
Related Concept Videos
 01:10
Control Systems
At the heart...
 01:16
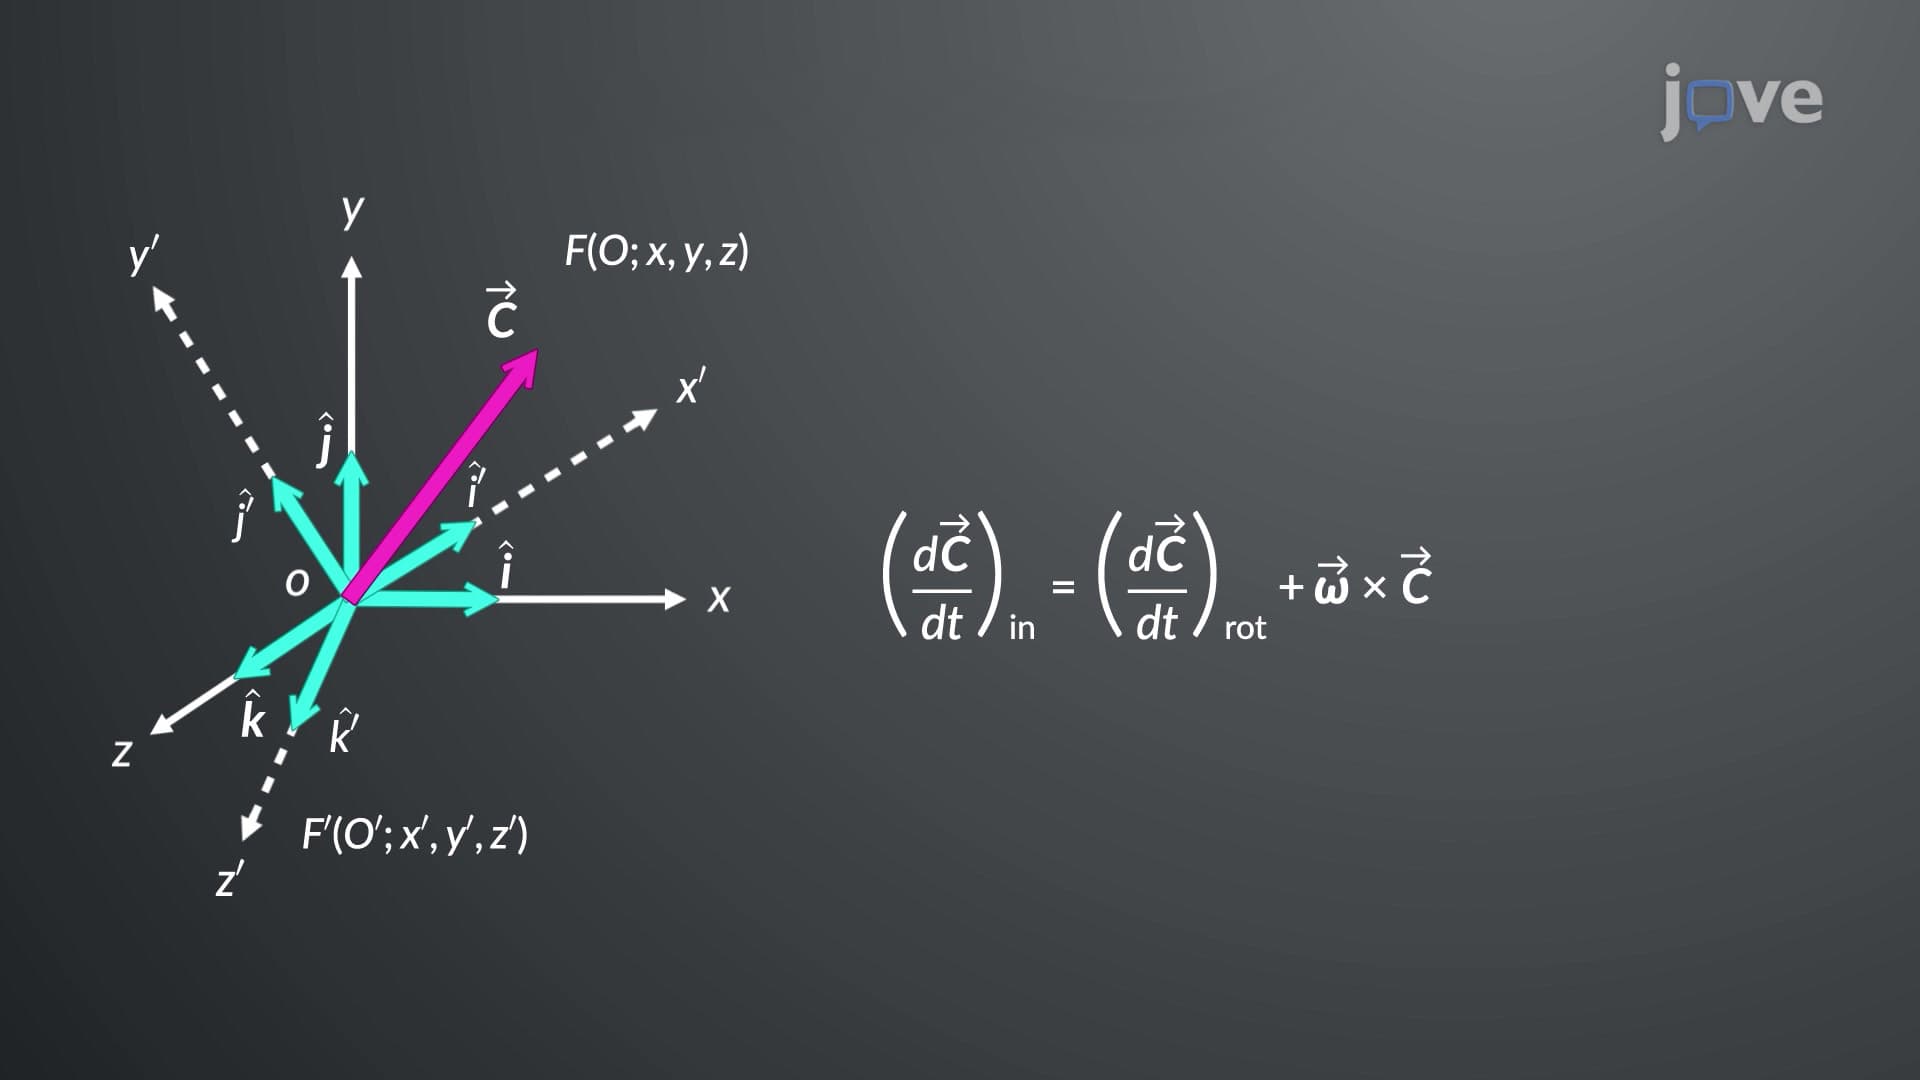
Vector Transformation in Rotating Coordinate Systems
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 02:57
Surface Tension, Capillary Action, and Viscosity
The various IMFs between identical molecules of a substance are examples of cohesive forces. The molecules within a liquid are surrounded by other molecules and are attracted equally in all directions by the cohesive forces within the liquid. However, the molecules on the surface of a liquid are attracted only by about one-half as many molecules. Because of the unbalanced molecular attractions on the surface molecules, liquids contract to form a shape that minimizes the number...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...