Related Experiment Video
Updated: Dec 11, 2025

Orthopedic Robot-Assisted Femoral Neck System in the Treatment of Femoral Neck Fracture
Published on: March 3, 2023
Indirect visual guided fracture reduction robot based on external markers
Zhuoxin Fu1, Hao Sun1, Xinyu Dong2,3
1School of Artificial Intelligence and Data Sicience, Hebei University of Technology, No.8 Guangrong Road, Hongqiao District, Tiajin, 300130, China.

Background:
Traditional fracture reduction surgery cannot ensure the accuracy of the reduction while consuming the physical strength of the surgeon. Although monitoring the fracture reduction process through radiography can improve the accuracy of the reduction, it will bring radiation harm to both patients and surgeons.
Methods:
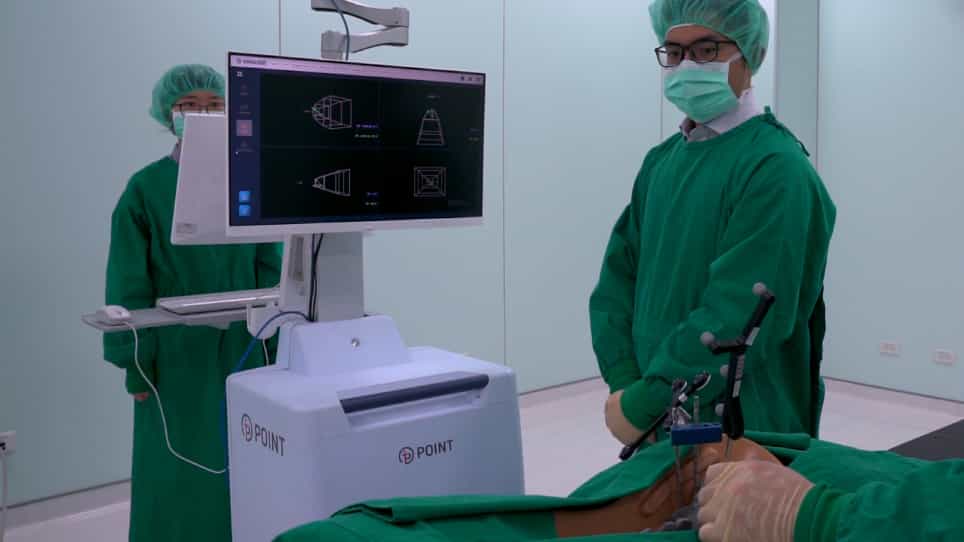
We proposed a novel fracture reduction solution that parallel robot is used for fracture reduction surgery. The binocular camera indirectly obtains the position and posture of the fragment wrapped by the tissue by measuring the posture of the external markers. According to the clinical experience of fracture reduction, a path is designed for fracture reduction. Then using position-based visual serving control the robot to fracture reduction surgery. The study is approved by the Rehabilitation Hospital, National Research Center for Rehabilitation Technical Aids, Beijing , China.
Results:
10 virtual cases of fracture were used for fracture reduction experiments. The simulation and model bone experiments are designed respectively. In model bone experiments, the fragments are reduction without collision. The angulation error after the reduction of this method is:3.3°±1.8°, and the axial rotation error is 0.8°±0.3°, the transverse stagger error and the axial direction error after reduction is 2mm±0.5mm and 2.5mm±1mm. After the reduction surgery, the external fixator is used to assist the fixing, and the deformity will be completely corrected.
Conclusions:
The solution can perform fracture reduction surgery with certain accuracy and effectively reduce the number of radiographic uses during surgery, and the collision between fragments is avoided during surgery. This article is protected by copyright. All rights reserved.