The three-dimensional measurement of unconstrained motion using a model-matching method
Related Experiment Video
Updated: Aug 14, 2026

MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
1Faculty of Science and Technology, Keio University, Yokohama-shi, Japan.

Abstract:
The measurement of motion is a basic technique for the quantitative mechanical analysis of human movement. However, previous methods of motion measurement using goniometry and surface markers have several associated problems: goniometers constrain human motion; and surface markers are missed, etc. To resolve these problems, a new technique of motion measurement using image processing is proposed. In this method, movements of the whole body are captured as image information, and a geometric model of a human body is fitted onto the contours of the image sequences. The joint angles are then estimated from the model. Usually, every segment has to be coloured separately so as to fit the geometric model automatically into the images; furthermore, this takes a very long time to process. Therefore, we reduced the processing time using the information in the overlap area between the models and images, instead of contour information. We estimated the joint angles of hidden segments with the grey scale image information. Thus there is no need to colour segments and attach surface markers; and unconstrained motion can be measured. Using the method developed, three-dimensional motion of the fingers including 21 segments was measured in 3-5 min per frame by a personal computer. The errors are 2 degrees maximally.
Related Concept Videos
 01:30
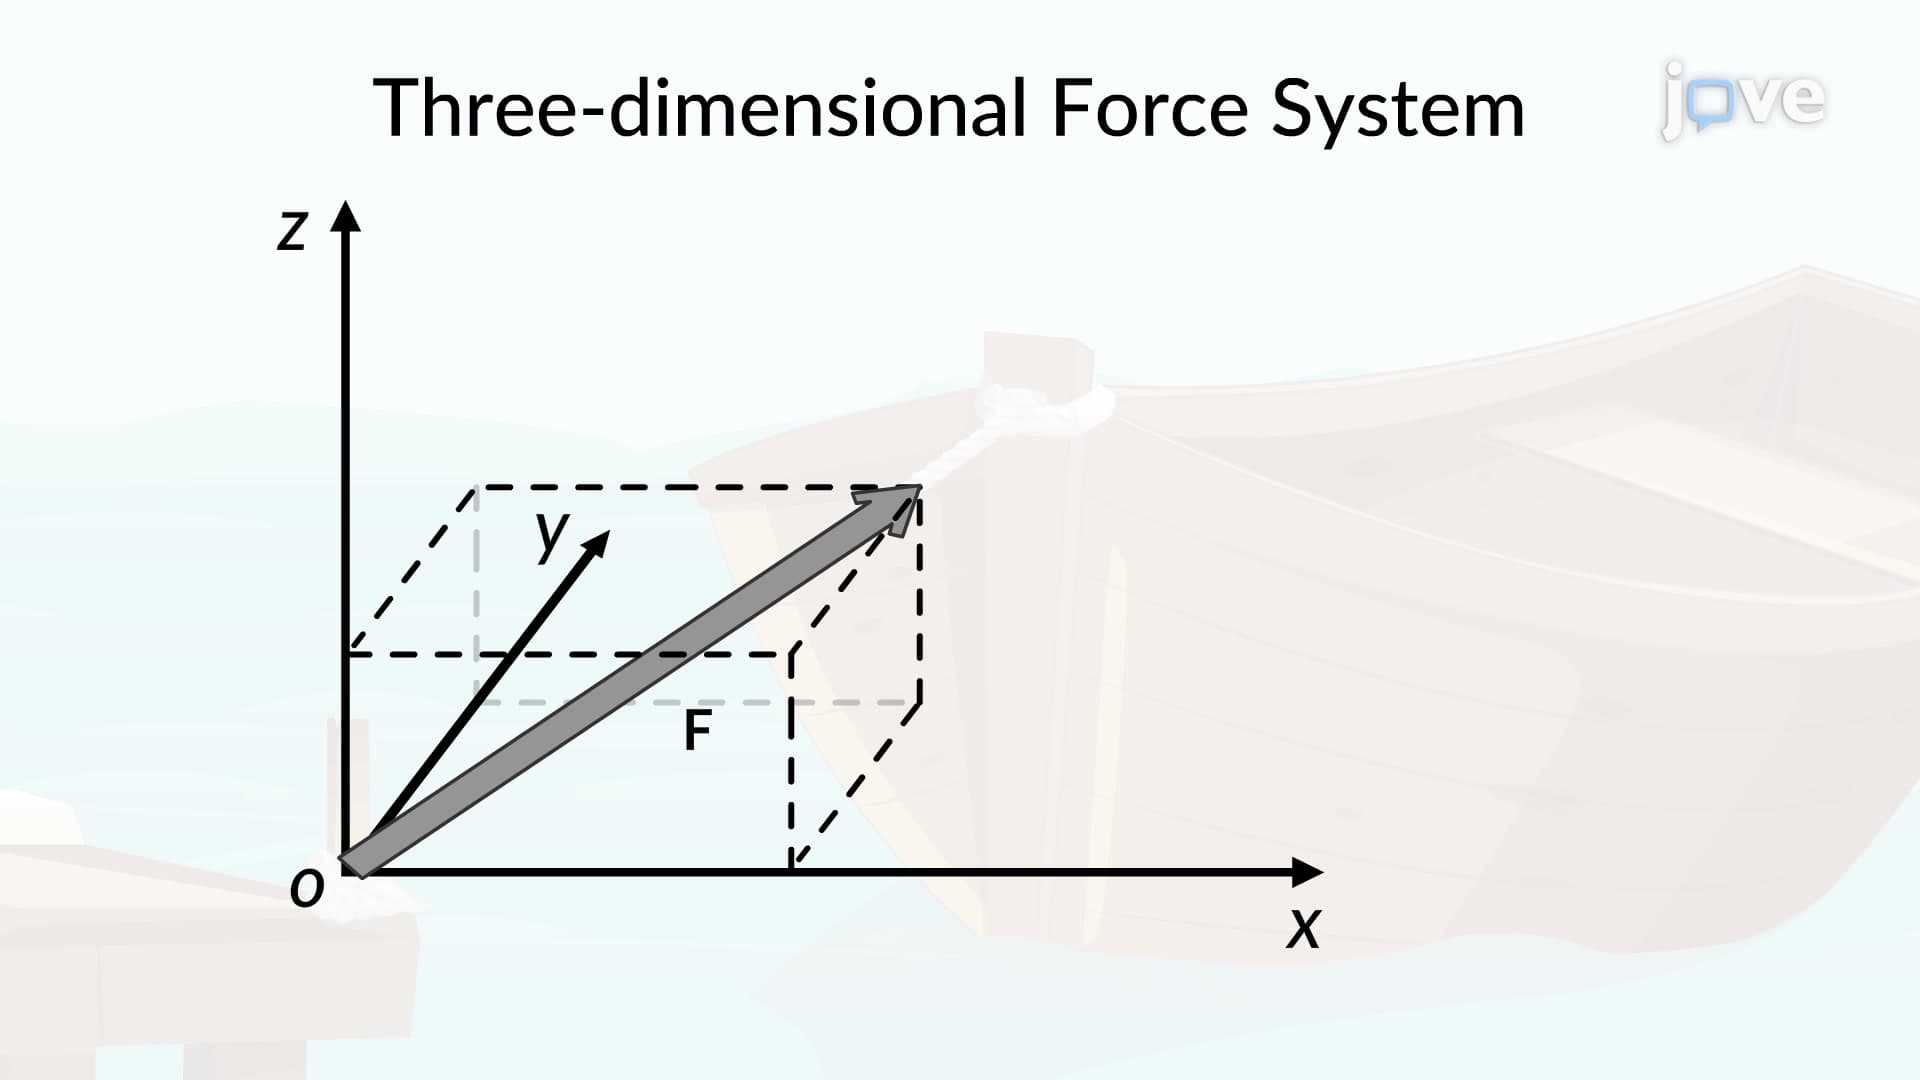
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...